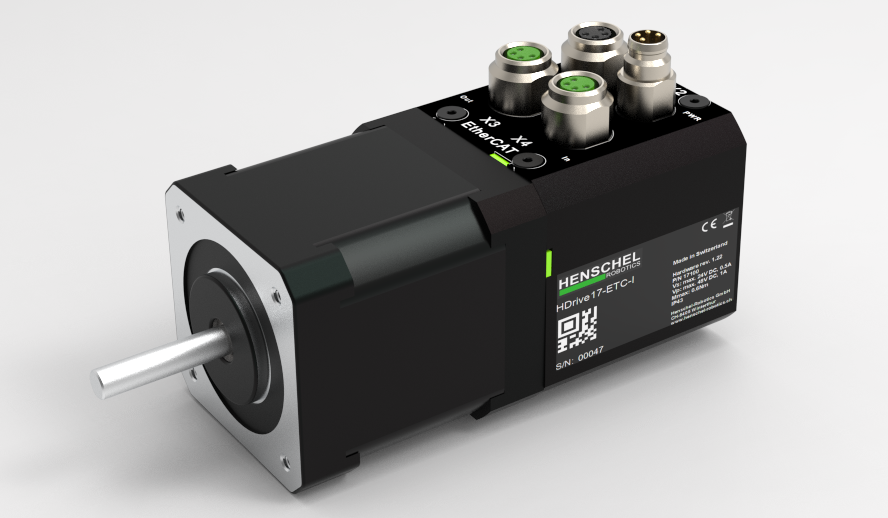
Ethernet · PC
HDrive17-ETH
NEMA17 over standard Ethernet. Python, C# or browser. No PLC required.
- Size
- 42 × 42 × 88 mm
- Stall
- 0.6 Nm
- Supply
- 12–24 V DC
Swiss Made · Winterthur
Henschel Robotics
Ultra-compact drives with motor, power stage, encoder and FOC control in one housing. Built for robotics and industrial automation.
Field-oriented control
Closed-loop FOC aligns rotor and stator fields for servo-class motion from a compact electromechanical core. Torque ripple compensation keeps output torque nearly constant, for accurate positioning and precise force control.
Product line
Ethernet for PC control, EtherCAT for hard real-time PLC systems. Motor, electronics and motion control in one Swiss-made unit.
Ethernet · PC
NEMA17 over standard Ethernet. Python, C# or browser. No PLC required.
EtherCAT · CiA 402
NEMA17 EtherCAT servo. TwinCAT, Codesys or any master. Typical cycle 1 ms (min. 50 µs).
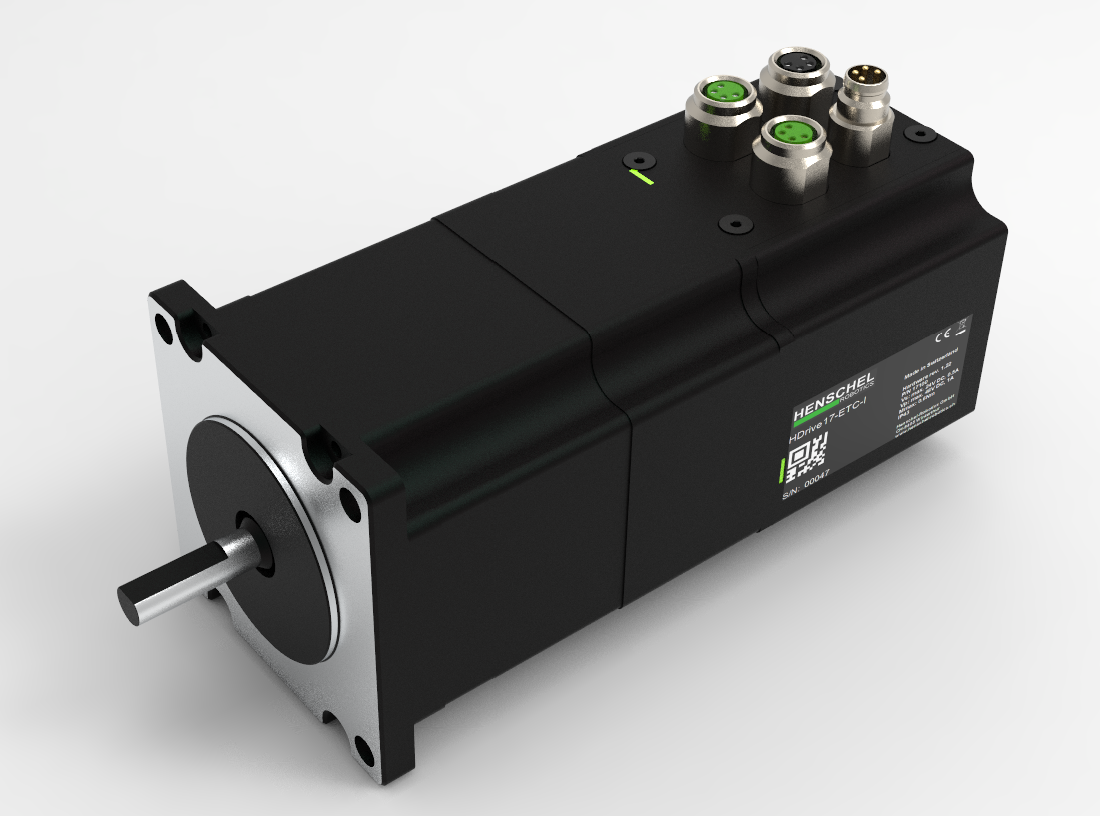
EtherCAT · higher torque
NEMA23 EtherCAT. Same industrial stack, more stall torque for heavier axes.
Control paths
The normal path for HDrive-ETC is a PLC. Python on a PC suits smaller projects without hard real-time requirements.
Company
Designed and built in Winterthur. Advanced control research with ZHAW, supported by Innosuisse.